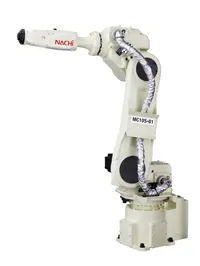
Payload
20kg1
Jumlah sendi
7
Ringkasan
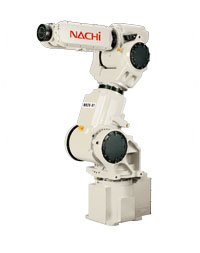
Kenapa MR20/20L
7-axes structure
- Flexible and complex positioning and motion can be available by 7-axes structure. Compact body, powerful arm
- Minimizing installation space.
- Payload 20kg MAX 30kg (Limited envelope within 30kg) Controller
- FD11
Katalog MR20/20LPDF resmi dari NACHI
Butuh saran atau harga?Tim penjualan kami membalas dalam 1 hari kerja
Spesifikasi Teknis
| Specification | MR20-02 | MR20L-01 |
|---|---|---|
| Robot model | MR20-02 | MR20L-01 |
| Construction | Articulated construction | Articulated construction |
| Number of axes | 7 | 7 |
| Drive system | AC servo system | AC servo system |
| Max. operating area JT1 | +/-3.14rad (+/-180°) | +/-3.14rad (+/-180°) |
| JT2 | +0.96 to -2.09rad (+55 to -120°) | +0.96 to -2.09rad (+55 to -120°) |
| JT7 | +/-3.14rad (+/-180°) | +/-3.14rad (+/-180°) |
| JT3 | +2.35 to -2.89rad (+135 to -166°) | +2.35 to -2.89rad (+135 to -166°) |
| JT4 | +/-3.14rad (+/-180°) | +/-3.14rad (+/-180°) |
| JT5 | +/-2.35rad (+/-135°) | +/-2.42rad (+/-139°) |
| JT6 | +/-6.28rad (+/-360°) | +/-6.28rad (+/-360°) |
| Max. speed JT1 | 2.96rad/s (170°/s) | 2.96rad/s (170°/s) |
| JT2 | 2.96rad/s (170°/s) | 2.96rad/s (170°/s) |
| JT7 | 2.96rad/s (170°/s) | 2.96rad/s (170°/s) |
| JT3 | 2.96rad/s (170°/s) | 2.96rad/s (170°/s) |
| JT4 | 4.36rad/s (250°/s) | 6.28rad/s (360°/s) |
| JT5 | 4.36rad/s (250°/s) | 6.28rad/s (360°/s) |
| JT6 | 5.23rad/s (300°/s) | 10.5rad/s (600°/s) |
| Payload | 20kg*1 | 20kg |
| Wrist torque JT4 | 80.8N·m | 49N·m |
| JT5 | 80.8N·m | 49N·m |
| JT6 | 44.1N·m | 23.5N·m |
| Wrist moment of inertia JT4 | 6.0kg·m² | 1.6kg·m² |
| JT5 | 6.0kg·m² | 1.6kg·m² |
| JT6 | 2.3kg·m² | 0.8kg·m² |
| Position repeat accuracy | +/-0.06mm | +/-0.06mm |
| Maximum working air pressure | 0.49MPa (5.0kgf/cm²) or less | 0.49MPa (5.0kgf/cm²) or less |
| Ambient temperature | 0 to 45℃ | 0 to 45℃ |
| Installation parameters | Floor mounted/ceiling mounted | Floor mounted/ceiling mounted |
| Environmental resistance | Meets the IP65 standard (for dust and waterproofing) | Meets the IP65 standard (for dust and waterproofing) |
| Robot mass | 230kg | 230kg |