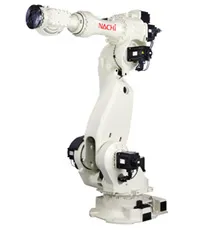
Payload
400 kg
Jumlah sendi
6
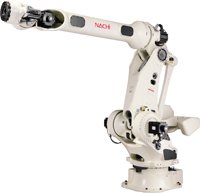
Repeatability
±0.09 mm
Ringkasan
Kenapa MC400L
Hollow wrist structure
- Avoiding interference of cables with peripheral equipment.
- Improved reliability of cables due to its stable behavior with wrist movement. High-speed motion
- Top level performance in its class. Powerful wrist
- Easy handling for large work-pieces due to the large wrist capacity.
- A work-piece of large moment of inertia is also available. Advanced applicability
- Wide envelope.
- 5 meter vertical stroke. Application signals are standard
- 2 ports for air, 40 application signals, DeviceNet cable, LAN cable.
Jangkauan gerak
Gerak tiap sendi robot.
Rentang gerak (−360° … +360°)
Kecepatan maks. (°/s)
J1Swivel
-180°
+180°
90
J4Rotation
-210°
+210°
110
J5Bend
-120°
+120°
110
J6Rotation
-360°
+360°
180
Katalog MC400LPDF resmi dari NACHI
Butuh saran atau harga?Tim penjualan kami membalas dalam 1 hari kerja
Spesifikasi Teknis
| Item | Specification |
|---|---|
| Robot model | MC400L-01 |
| Structure | Articulated |
| Number of axes | 6 |
| Drive system | AC servo system |
| Max. operating envelope | |
| J1 (Swivel) | ±3.14 rad (±180°) |
| J2 (Forward/Backward) | -1.83 ~ +1.05 rad (-105 ~ +60°) |
| J3 (Upward/Downward) | -2.27 ~ +0.52 rad (-130 ~ +30°) |
| J4 (Rotation) | ±3.67 rad (±210°) |
| J5 (Bend) | ±2.09 rad (±120°) |
| J6 (Rotation) | Max.: ±6.28 rad (±360°) |
| Initial setting: ±3.67 rad (±210°) *4 | |
| Max. velocity | |
| J1 | 1.57 rad/s (90°/s) |
| J2 | 1.57 rad/s (90°/s) |
| J3 | 1.57 rad/s (90°/s) |
| J4 | 1.92 rad/s (110°/s) |
| J5 | 1.92 rad/s (110°/s) |
| J6 | 3.14 rad/s (180°/s) |
| Payload | |
| Wrist | 400 kg |
| Forearm *1 | Max. 50 kg |
| Allowable static load torque for wrist | |
| J4 (Rotation) | 3450 N·m |
| J5 (Bend) | 3450 N·m |
| J6 (Rotation) | 1725 N·m |
| Allowable moment of inertia for wrist *2 | |
| J4 | 600 kg·m² |
| J5 | 600 kg·m² |
| J6 | 400 kg·m² |
| Position repeatability *3 | ±0.09 mm |
| Installation | Floor |
| Ambient conditions | |
| Ambient temperature *5 | 0 ~ 45°C |
| Ambient humidity | 20 ~ 85% RH (without condensation) |
| Vibration | Not more than 0.5G (4.9 m/s²) |
| Robot mass | 3,050 kg |