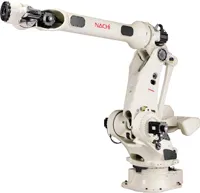
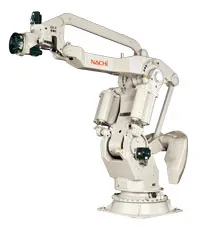
Payload
350 kg
Repeatability
±0.09 mm
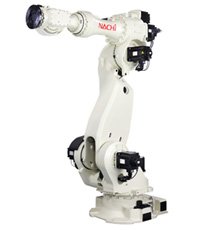
Jangkauan
2,771 mm
Berat
1,620 kg
NACHI Heavy Duty Robots Ada
MC350/MC280/MC470P
Linkage-less construction is simple and compact
Ringkasan
Kenapa MC350/MC280/MC470P
Linkage-less construction is simple and compact
- Simple construction has no counterweights or parallel linkage.
- Compact form can be installed in small places. Expansive operating stroke and lifting capabilities
- Plenty of wrist torque (1.7 times our existing model) easily handles large work pieces.
- Long arm type (MC280L) has maximum reach of 3,101 mm
- Super heavy lifting type (MC470P) can lift up to 470 kg (wrist must be directed downward) High-speed motion
- Lower weight and greater rigidity make it the fastest robot in its class.
- Reduce cycle times by up to 15% (compared to our existing model).
Jangkauan gerak
Gerak tiap sendi robot.
Rentang gerak (−360° … +360°)
Kecepatan maks. (°/s)
J1
-180°
+180°
95
J2
-100°
+40°
95
J3
-180°
+130°
110
J4
-360°
+360°
110
J5
-125°
+125°
110
Katalog MC350/MC280/MC470PPDF resmi dari NACHI
Butuh saran atau harga?Tim penjualan kami membalas dalam 1 hari kerja
Spesifikasi Teknis
| Item | MC350-01 | MC280L-01 | MC470P-01 |
|---|---|---|---|
| Robot model | MC350-01 | MC280L-01 | MC470P-01 |
| Structure | Articulated construction | Articulated construction | Articulated construction |
| No. of axes | 6 | 6 | 6 |
| Drive system | AC servo system | AC servo system | AC servo system |
| Max. working envelope | |||
| J1 Swivel | ±3.14 rad (±180°) | ±3.14 rad (±180°) | ±3.14 rad (±180°) |
| J2 Horizontal | -1.75 to +0.70 rad (-100° to +40°) | -1.75 to +0.70 rad (-100° to +40°) | -1.75 to +0.70 rad (-100° to +40°) |
| J3 Vertical | -3.14 to +2.27 rad (-180° to +130°) | -2.57 to +2.27 rad (-147° to +130°) | -3.14 to +0.61 rad (-180° to +35°) |
| J4 Rotation 2 | ±6.28 rad (±360°) | ±6.28 rad (±360°) | ±6.28 rad (±360°) *5 |
| J5 Bend | ±2.18 rad (±125°) | ±2.18 rad (±125°) | ±2.18 rad (±125°) |
| J6 Rotation 1 | — | ±6.28 rad (±360°) | — |
| Max. speed | |||
| J1 Swivel | 1.66 rad/s (95°/s) | 1.83 rad/s (105°/s) | 1.66 rad/s (95°/s) |
| J2 Horizontal | 1.66 rad/s (95°/s) | 1.66 rad/s (95°/s) | 1.66 rad/s (95°/s) |
| J3 Vertical | 1.92 rad/s (110°/s) | 2.09 rad/s (120°/s) | 1.92 rad/s (110°/s) |
| J4 Rotation 2 | 1.92 rad/s (110°/s) | 2.09 rad/s (120°/s) | 1.92 rad/s (110°/s) |
| J5 Bend | 1.92 rad/s (110°/s) | 2.09 rad/s (120°/s) | 1.92 rad/s (110°/s) |
| J6 Rotation 1 | 3.14 rad/s (180°/s) | 3.49 rad/s (200°/s) | 3.14 rad/s (180°/s) |
| Payload | |||
| Wrist | 350 kg | 280 kg | 470 kg |
| Forearm *1 | Max. 50 kg | Max. 25 kg | Max. 30 kg |
| Allowable static load torque | |||
| J4 Rotation 2 | 2750 N·m | 1921 N·m | 2750 N·m |
| J5 Bend | 2750 N·m | 1921 N·m | 2750 N·m |
| J6 Rotation 1 | 1235 N·m | 988 N·m | 0 N·m |
| Max. allowable moment of inertia *2 | |||
| J4 Rotation 2 | — | 400 kg·m² | — |
| J5 Bend | — | 400 kg·m² | — |
| J6 Rotation 1 | — | 250 kg·m² | — |
| Max. reach | 2,771 mm | 3,101 mm | 2,771 mm |
| Position repeatability *3 | ±0.09 mm | ±0.09 mm | ±0.09 mm |
| Ambient temperature | 0 to 45 °C | 0 to 45 °C | 0 to 45 °C |
| Ambient humidity | 20 to 85% RH (without condensation) | 20 to 85% RH (without condensation) | 20 to 85% RH (without condensation) |
| Vibration | 0.5G or less | 0.5G or less | 0.5G or less |
| Installation | Floor mount | Floor mount | Floor mount |
| Robot weight | 1,620 kg | 1,700 kg | 1,620 kg |