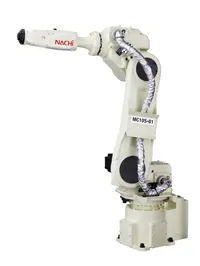
Payload
12 kg
Jumlah sendi
6
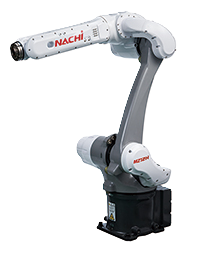
Repeatability
±0.04 mm
Jangkauan
1454 mm
NACHI Handling Robots Ada
MZ12H/15H
Powerful and compact.Integrated valves in the arm and smart cable and hose routing through the hollow wrist
Ringkasan
Kenapa MZ12H/15H
Powerful and compact.Integrated valves in the arm and smart cable and hose routing through the hollow wrist.
Jangkauan gerak
Gerak tiap sendi robot.
Rentang gerak (−360° … +360°)
Kecepatan maks. (°/s)
J1
-170°
+170°
260
J2
-160°
+90°
230
J3
-147°
+210°
260
J4
-190°
+190°
470
J5
-140°
+140°
470
J6
-360°
+360°
740
Katalog MZ12H/15HPDF resmi dari NACHI
Butuh saran atau harga?Tim penjualan kami membalas dalam 1 hari kerja
Spesifikasi Teknis
| Item | Specification | MZ12H-01 | MZ15H-01 |
| Model | MZ12H-01 | MZ15H-01 | |
| Structure | Articulated robot | ||
| Axes | 6 | ||
| Drive System | AC servo motor | ||
| Max. Motion Range | J1 | ±2.97 rad (±170°) | |
| J2 | +1.57 ~ -2.79 rad (+90° ~ -160°) | ||
| J3 | +3.67 ~ -2.57 rad (+210° ~ -147°) | ||
| J4 | ±3.32 rad (±190°) | ||
| J5 | ±2.44 rad (±140°) | ±2.36 rad (±135°) | |
| J6 | ±6.28 rad (±360°) | ||
| Max. Velocity¹ | J1 | 4.54 rad/s (260°/s) | |
| J2 | 4.01 rad/s (230°/s) | ||
| J3 | 4.54 rad/s (260°/s) | ||
| J4 | 8.20 rad/s (470°/s) | ||
| J5 | 8.20 rad/s (470°/s) | 4.88 rad/s (280°/s) | |
| J6 | 12.92 rad/s (740°/s) | 10.82 rad/s (620°/s) | |
| Max. Payload | Wrist | 12 kg | 15 kg |
| Max. Static Load Torque | J4 | 26.5 N·m | 35.0 N·m |
| J5 | 26.5 N·m | 35.0 N·m | |
| J6 | 12.0 N·m | 15.0 N·m | |
| Max. Moment of Inertia² | J4 | 0.9 kg·m² | 1.6 kg·m² |
| J5 | 0.9 kg·m² | 1.6 kg·m² | |
| J6 | 0.3 kg·m² | 0.8 kg·m² | |
| Position Repeatability³ | ±0.04 mm | ||
| Maximum Reach | 1454 mm | ||
| Air Tubes | ø6 × 2, ø8 × 1 | ||
| Application Cables | 24 wires (incl. wires for optional valves) | ||
| Installation | Floor / Inverted / Angle | Floor / Inverted | |
| Mounting Condition | Ambient Temperature | 0 ~ 45°C⁴ | |
| Ambient Humidity | 20 ~ 85% RH (No condensation) | ||
| Vibration | ≤ 0.5G (4.9 m/s²) | ||
| Protection Class⁵ | IP67 Equivalent (Dust-proof, liquid-resistant) | ||
| Robot Weight | 155 kg |